Page Not Found
Page not found. Your pixels are in another canvas.
A list of all the posts and pages found on the site. For you robots out there is an XML version available for digesting as well.
Page not found. Your pixels are in another canvas.
| AI & Robotics Engineer | Computer Vision | Machine Learning | Intelligent Systems |
This is a page not in th emain menu
Published:
The third part of my robotics kinematics series explores how to compose rotations and describe orientation using Euler angles and roll–pitch–yaw. It connects these angle representations to rotation matrices and the problem of recovering angles from a given orientation.
Published:
The second part of my robotics kinematics series explains the geometry behind rotation matrices. It covers rotations around the coordinate axes, changes of basis, and the relationship between rotating a reference frame and rotating a vector.
Published:
The first part of my robotics kinematics series introduces position, orientation, and reference frames. Starting with vectors and trigonometry, it builds the rotation matrix representation and explains how to transform coordinates between frames.
Published:
A practical guide to setting up the Raspberry Pi Camera Module v2.1, based on the IMX219 sensor, on Ubuntu 24.04 LTS. The article covers camera setup and troubleshooting for this hardware and operating system combination.
Published:
title: “ROS2 humble” excerpt: “ Docker file and docker build. “ —
Published:
A practical introduction to semantic segmentation with TensorFlow, fully convolutional networks, and transfer learning. The article explores FCN-8, FCN-16, and FCN-32, using VGG16 as an encoder, and evaluating segmentation with intersection over union and Dice score.
Published:
The paper discusses Fully Convolutional Networks for Semantic Segmentation by Jonathan Long, Evan Shelhamer, and Trevor Darrell from UC Berkeley. The authors introduce fully convolutional networks (FCNs) as a powerful approach for semantic segmentation, surpassing existing methods in pixel-wise prediction. The key innovation is to replace fully-connected layers with convolutional layers, allowing for end-to-end training and efficient inference on arbitrary-sized inputs. The FCN architecture incorporates both deep, coarse semantic information and shallow, fine appearance information for accurate segmentations. The paper reviews related work, emphasizes the efficiency of fully convolutional training over patchwise methods, and demonstrates state-of-the-art results on various datasets. The authors compare their approach to adaptations of deep classification nets for semantic segmentation, highlighting the end-to-end learning capability of FCNs. 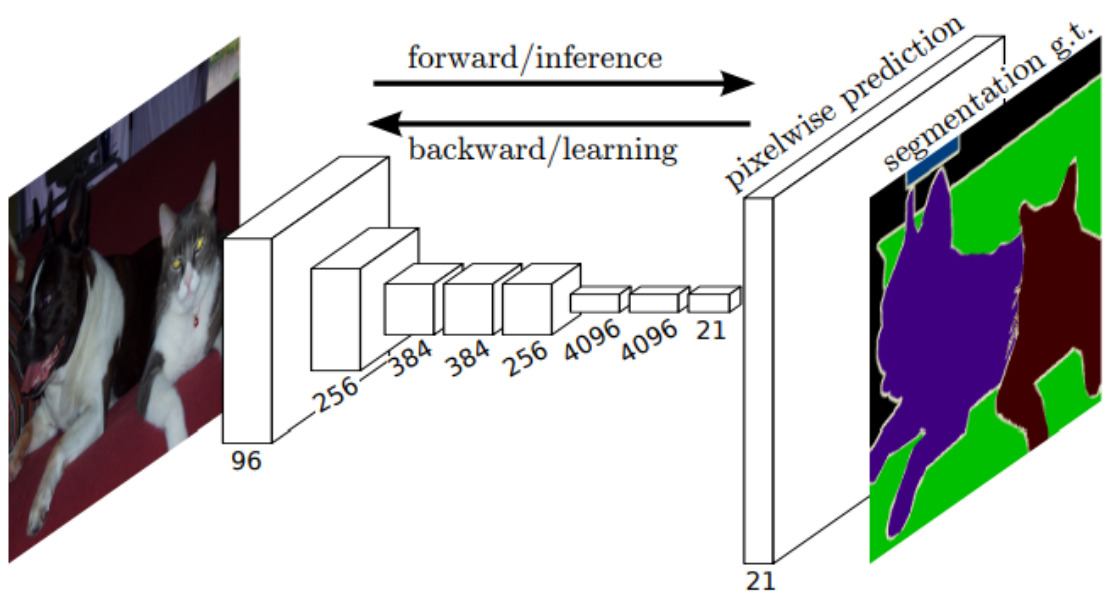
Published:
Image segmentation is a sophisticated technique in computer vision that involves partitioning an image into distinct, meaningful regions. Its primary objective is to analyze and understand the visual content within an image by assigning specific labels to different parts of the scene. This process aids in extracting valuable information for various applications, such as object recognition, scene understanding, and autonomous navigation. 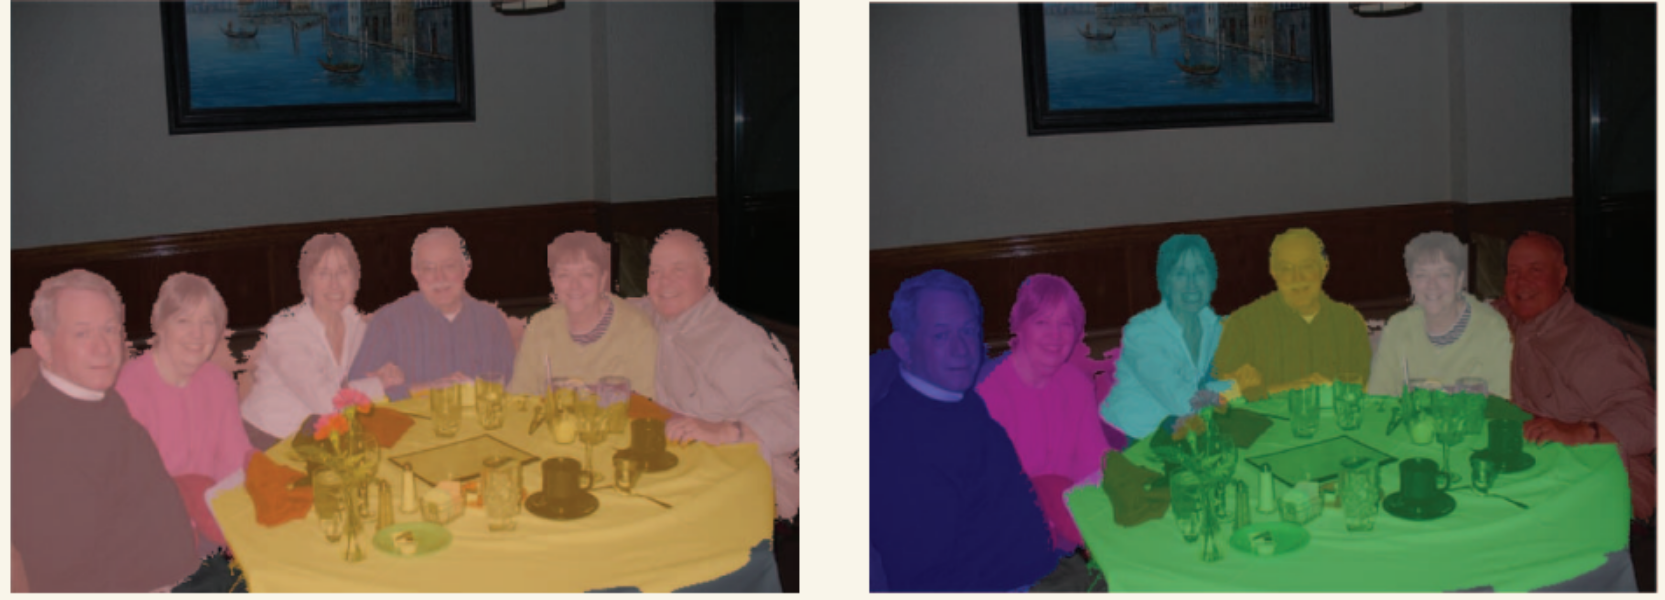
Published:
A practical guide to 3D point cloud segmentation with PointNet, Python, and PyTorch. This tutorial moves from the architecture to implementation, exploring how to work with unordered 3D points for segmentation.
Published:
PointNet is a clever deep learning approach for understanding 3D geometric data, like point clouds. Unlike other methods that transform data into regular grids or images, PointNet directly processes point clouds, respecting their irregular nature. It’s a simple yet powerful neural network that handles tasks such as object classification and part segmentation efficiently. The key is using a symmetric function, max pooling, which helps the network select important points in the cloud. It’s not just fast; it’s also robust to changes in input points. The project includes a theoretical analysis, showing PointNet’s ability to approximate various functions, and an experimental evaluation, demonstrating its speed and competitive performance compared to other approaches. The contribution lies in designing a deep net architecture for unordered 3D point sets, showcasing its effectiveness in multiple tasks and providing insights into its stability and efficiency.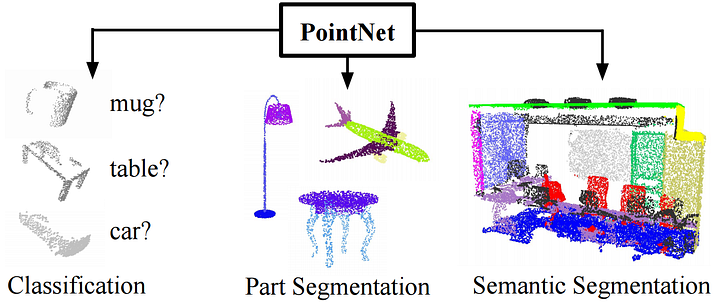
Published:
Welcome to the exciting world of Docker, where containerization opens up new possibilities in software development and deployment. In this journey, we will unravel the mysteries of Docker, guiding you step-by-step through the fundamentals. But that’s not all — brace yourself for a hands-on experience as we delve into installing Docker alongside ROS Noetic on Ubuntu 20.04.
Published:
An exploration of 3D reconstruction with Structure from Motion in C++. The article uses a series of smartphone images of a small scene to investigate how multiple views can reveal its three-dimensional structure.
Let’s explore Structure from Motion by figuring out the 3D layout of a small scene through a series of smartphone images. Choose nearby objects and take pictures with some overlap in what your camera captures. For accurate results, use a checkerboard to calibrate your camera — take a few shots from different angles. This calibration step provides vital info for the entire process.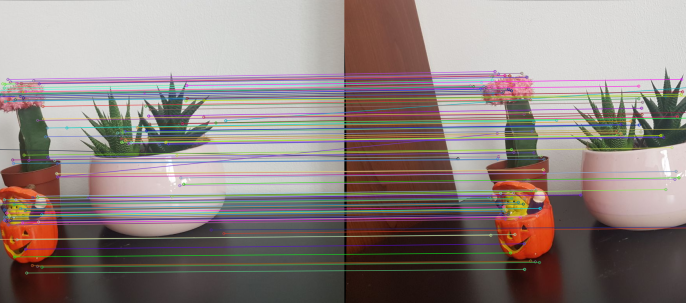
Get ready to explore the world of 3D segmentation as we take a journey through PointNet, a super cool way to understand 3D shapes. PointNet is like a smart tool for computers to look at 3D things, especially groups of points floating in space. It’s different from other methods because it works directly with these points, without forcing them into grids or pictures.
Published in Journal 1, 2009
This paper is about the number 1. The number 2 is left for future work.
Recommended citation: Your Name, You. (2009). "Paper Title Number 1." Journal 1. 1(1). http://academicpages.github.io/files/paper1.pdf
Published:
This is a description of your talk, which is a markdown files that can be all markdown-ified like any other post. Yay markdown!
Published:
This is a description of your conference proceedings talk, note the different field in type. You can put anything in this field.
Undergraduate course, University 1, Department, 2014
This is a description of a teaching experience. You can use markdown like any other post.
Workshop, University 1, Department, 2015
This is a description of a teaching experience. You can use markdown like any other post.